This robot can't stay up yet. It tried 17 times on the real robot: 12 swung up to near upright, none held it. Change one thing and see.
1Remix one
Two robots to start from: one built for real, with its own logs; one a design that has been tested in simulation.
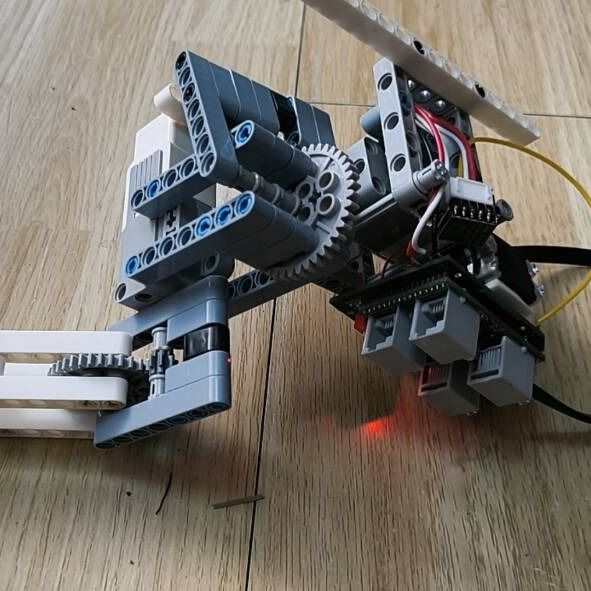 Real robot
The get-up robot
Two motors and MK Brain. The skill it is trying to learn: get back up after a fall.
- Built for real · its records show it swinging up to near upright
- On Nov 16–17 it tried 17 times on the real robot: 12 swung up to near upright, none held it.
Two-leg robot v4
Four medium motors and MK Brain. Its move cards: poses, marching in place, kicks and a small dance.
- A design, tested in simulation
- Has not walked yet
More robots
Body: the robot you start from · MK Brain: runs it · Skill: one thing it can do, with its code, setup and conditions.
2Change one thing
Tell it in your own words. It picks one change on this page; you can still move the slider yourself.
Before the marker it is the real log; after it, it is an estimate. Your setting has not been run on the real robot.
How reliable is this?
- Everything before the marked point is the real log. The robot behaved the same up to there, whatever the wait.
- The marked point is an estimate: it only says the lock condition would have been met there.
- After that point the log no longer applies. Whether the robot would then stay up is not known; it has not been run on the real robot with your setting.
- The only real locks we have: in run 26 it tipped past 30° again about 0.16 s later; in run 28 the log ends only about 0.27 s after the lock, with the tilt still jittering between 3.6° and 24°. Run 28 also has no data for about 2.2 s just before the lock.
These curves are computed from the move card, not measured. This robot has not walked yet.
How reliable is this?
- The curves are computed from the move card and the board's own rules (10 times a second, each joint at most the speed you set, every pose within ±40°). They are not measured.
- On the real robot a joint can lag; if it falls 15° behind, the board stops by itself. Whether your version keeps up is not known until it runs.
- “Walk” steps use the stepping pattern found in simulation. This robot has not walked yet.
3Save as a card
Your change becomes a card you can download: what it is a remix of, what you changed, and how strong the evidence is. It is a picture, not a robot.
Load a card
Open a card file, or paste its JSON. Loading only changes this page.