MK Play
Pick a robot. Change one thing. Keep your version.
Build the body. Share the skills.
Your ideas. In motion.
Everything here runs in your browser. Nothing on this page moves a robot.1Pick a robot
Two robots to start from: one built for real, with its own logs; one designed and tested in simulation.
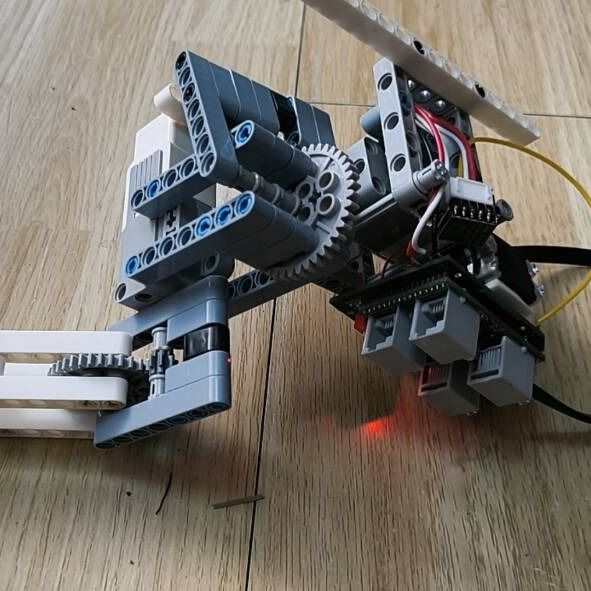
The get-up robot
Two motors and MK Brain. Its skill: get up after it falls over.
- Built for real · Nov 16–17: 17 runs, stood and held once
- Does not get up every time yet
Two-leg robot v4
Four medium motors and MK Brain. Its move cards: poses, steps and small dances.
- Designed and tested in simulation
- Has not walked yet
coming
More robots
Body
MK BrainMatch the connectors and power, connect MK Brain, and you can start controlling the motors.
SkillA robot skill packages something the robot can do with the code, setup, and conditions it needs.
2Change one thing
Say what to change
Tell it in your own words. It picks one change on this page; you can still move the slider yourself.
lock recorded in the real logwhat-if: lock condition met (estimate)cannot tell from this logno lock
REAL LOGS
WHAT-IF · ESTIMATE
What this can and cannot tell you
- Everything before the marked point is the real log. The robot behaved the same up to there, whatever the wait.
- The marked point is an estimate: it only says the lock condition would have been met there.
- After that point the log no longer applies. Whether the robot would then stay up is not known; it has not been run on the real robot with your setting.
- The only real locks we have: in run 26 it tipped past 30° again 0.16 s later; in run 28 it was still upright when the log ended 0.27 s later.
Pick a move card
DESIGN PREVIEW · COMPUTED
REAL RECORDSnone yetThere is no log from a real two-leg robot yet. Everything shown here is simulation or design preview.
What this can and cannot tell you
- The curves are computed from the move card and the board's own rules (10 times a second, each joint at most the speed you set, every pose within ±40°). They are not measured.
- On the real robot a joint can lag; if it falls 15° behind, the board stops by itself. Whether your version keeps up is not known until it runs.
- “Walk” steps use the stepping pattern found in simulation. This robot has not walked yet.
3Keep your version
Your change becomes a skill version card: code, setup, conditions, what it is based on, what you changed, and how strong the evidence is.
See the card as JSON
Load a card
Open a card file, or paste its JSON. Loading only changes this page.
Saved on this deviceWhere this stands
On the real get-up robot, Nov 16–17: 17 runs, it stood and held once (run 28). It does not get up every time yet.
Its curves on this page come from the robot's own logs (runs 23–40, Nov 15–17, 2026).
The two-leg robot v4 is designed and tested in simulation. It has not walked yet.
The two-leg robot's picture and curves here are simulation and design previews, not photos or measurements.
Changed versions are design previews. None has been run on a real robot yet.
Publishing your version to a public directory is not open yet. Your card stays with you.
More robots: coming.